
RIG-TARS combines an ESP32-S3, three servo-driven sections and voice interaction in a 3D-printable robot, with firmware and development resources available openly.
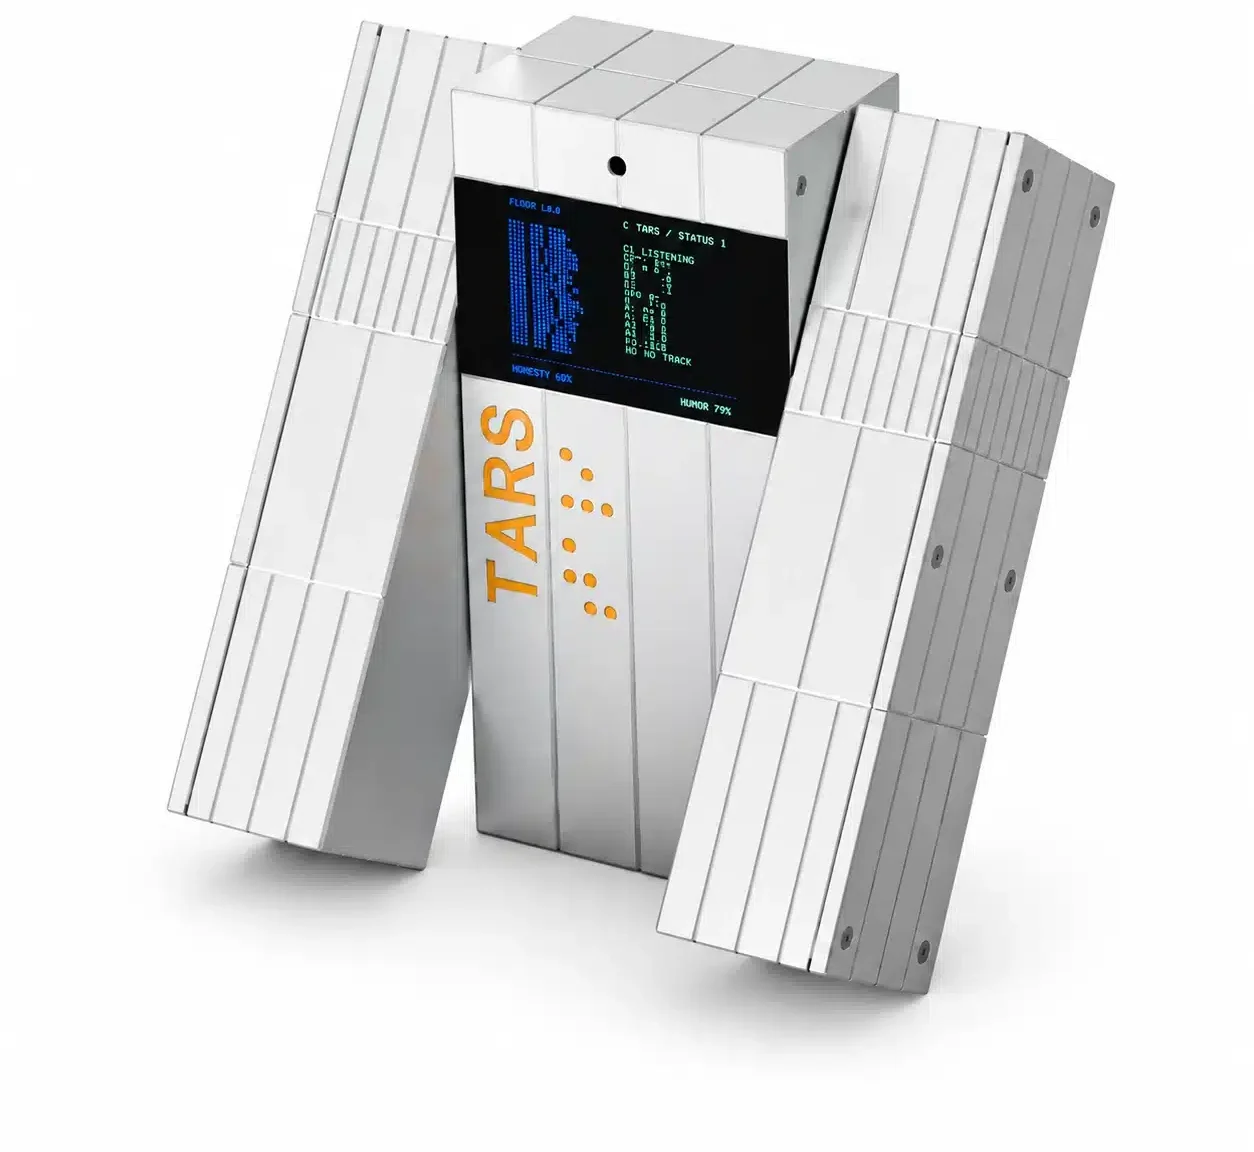
RIG-TARS, a desktop robot based on a science-fiction concept, serves as a platform for exploring robotics, voice communication and embedded artificial intelligence. The robot was developed by LuwuDynamics, and it features an ESP32-S3 microcontroller as well as three segments that allow walking and turning through voice commands. The robot’s software is called RIG-Omni and it is available for inspection on GitHub.
The robot uses three UART-controlled SCS009 serial servos to move its segmented body. The movement and positioning is controlled by using the data from the six-axis IMU QMI8658C that senses the positioning of the robot. There is a 2.4 inches colour screen with a 320 × 240 resolution used as the console of the robot.
Apart from motion controls, the RIG-TARS also features a mic and a speaker which allow voice interactions. The wake-word detection is done locally by the ESP32-S3, but speech recognition and synthesis is done via cloud-based services. The firmware of the RIG-TARS also has built-in support for controlling the robot via Bluetooth LE, OTA updates and Model Context Protocol (MCP) tools.
The code for the open-source firmware has been developed using C++ and the ESP-IDF from the Espressif company. One exciting thing about the code is that the same RIG-Omni code base works with four robot variations such as TARS, Robotic Arm, balancing robot and Robot dog. The developers are able to choose their hardware
The kit is priced at $99, but only comes with the electronics. It does not have the printed shell. One will be required to print the shell on one’s own. Mechanical design files can be accessed through the repository. Developers that wish to make commercial alterations must first determine the licensing of the repository since it uses Apache 2.0 licensing.
For more information, click here.