
ZeroWire Robotics is developing a palm-sized robot dog with accessible hardware designs, firmware and Python tools for custom robotics experiments.
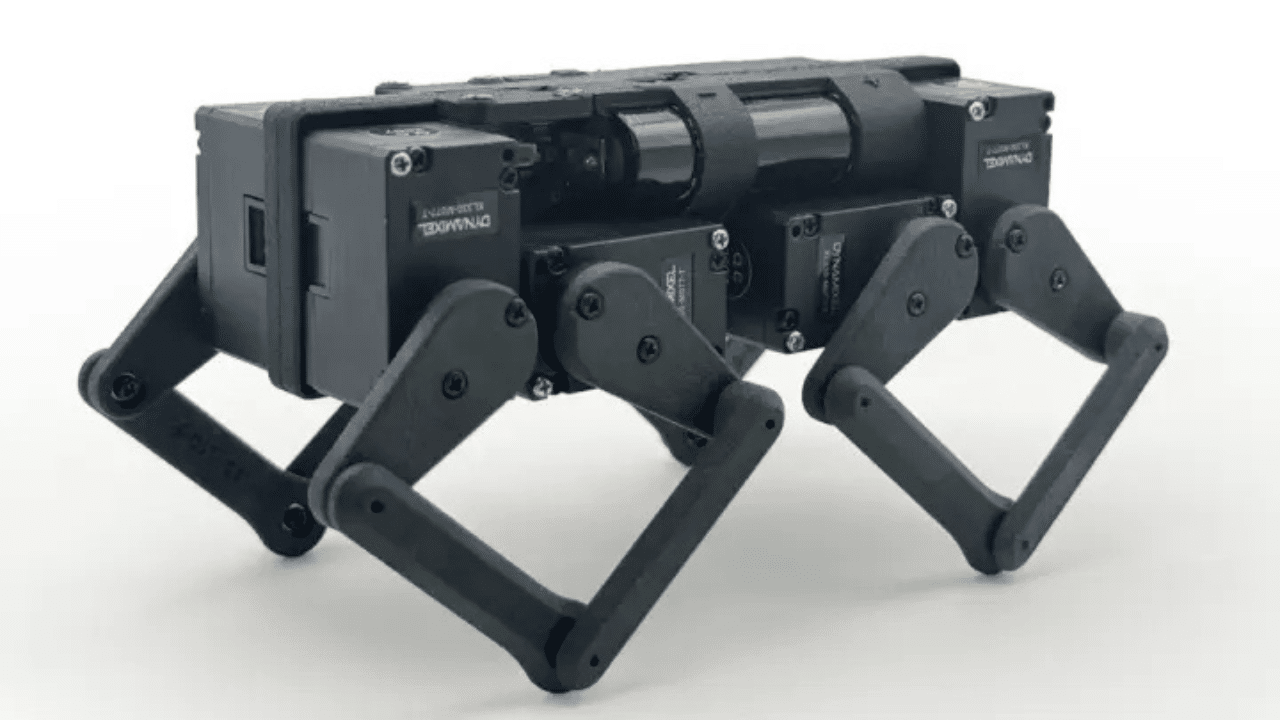
Q8botOne is an open-source quadruped robot developed by ZeroWire Robotics, designed to let developers explore robot locomotion, embedded control and hardware modification on a compact platform. The project builds on the original Q8bot, a home-built quadruped whose hardware designs and software are available publicly. ZeroWire Robotics plans to extend this approach to Q8botOne, with mechanical designs, electronics and software intended to be accessible for developers who want to study or customise the robot rather than use it as a closed product.
The original project’s public resources include 3D CAD models, STL files, PCB designs, schematics, Gerber files, a bill of materials, firmware and Python control tools. These files allow makers to manufacture components, assemble the electronics, inspect the circuit design and modify the control software. The repository also provides build and setup guidance, offering a starting point for developers interested in reproducing the robot or adapting its design for their own experiments.
Q8botOne uses an ESP32-C3 microcontroller for wireless communication and embedded control, alongside eight ROBOTIS DYNAMIXEL XL330-M077-T smart actuators. Unlike conventional hobby servos, these actuators support position and velocity control, joint feedback and adjustable proportional-integral-derivative (PID) parameters. This gives developers access to motion-control data that can be used to experiment with gait generation, balance and coordinated leg movement. The robot measures approximately 120 × 70 × 70mm and weighs around 221–250g, depending on its configuration.
The hardware adopts a wire-free internal architecture, with the components connecting directly to a central PCB that also serves as the robot’s structural spine. Optional additions include an MPU-6050 inertial measurement unit for motion sensing and an ESP32 camera module for visual feedback. A separate ESP32-C3 wireless controller supports direct operation and can act as a computer-connected interface for a desktop control application, an Xbox controller or custom software using the project’s API.
Q8botOne is being promoted through a Crowd Supply campaign, and the developer plans to publish its design files and code as the project progresses. Until those materials are released, the original Q8bot repository provides the available reference for hardware construction and software development. By carrying forward the open-source approach into a more integrated quadruped design, ZeroWire Robotics aims to give makers and researchers a compact platform for investigating embedded robotics, smart-actuator control and custom locomotion algorithms. The availability and terms of the final Q8botOne hardware and software releases will determine how far the community can reproduce and adapt the complete design.