
An open source quadruped uses modified hobby servos, custom PCBs and a 200Hz control loop to bring closed-loop robotics to a DIY build.
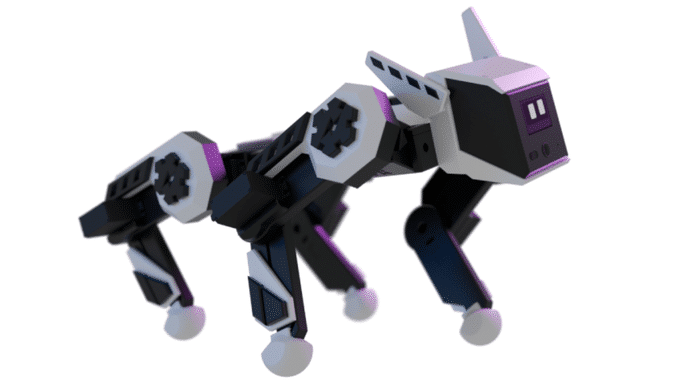
The TNY-360 is an open-source quadruped robot developed by TNY Robotics, with its mechanical designs, electronics and firmware available through a public GitHub repository. The project gives makers, educators and robotics developers access to the files needed to assemble the robot from individual components, rather than relying entirely on a pre-built commercial platform. Its repository includes computer-aided design (CAD) files, printed circuit board (PCB) layouts, a bill of materials (BOM), firmware and supporting documentation. The project is licensed under Creative Commons Attribution-NonCommercial-ShareAlike 4.0 (CC BY-NC-SA 4.0), permitting sharing and adaptation for non-commercial purposes with attribution and the same licence.
The hardware files include FreeCAD designs, 3D-printable STL and 3MF models, PCB manufacturing files and component lists. These resources allow builders to manufacture replacement parts, modify the robot’s enclosure, reproduce circuit boards and adapt its mechanical structure. The modular electronics use standard JST-PH connectors, while an expansion port supports additional hardware. This design approach makes repair and customisation part of the development process.
At the centre of the robot is an ESP32-S3 N16R8 module, which manages its control and communication functions. Its firmware separates time-sensitive motion control from higher-level tasks such as the user interface and WebSocket communication. A dedicated control loop runs at 200Hz, while 12 modified MG996R servo motors drive the legs. The servo modifications use a custom operational-amplifier buffer circuit to provide position feedback, enabling closed-loop control rather than relying solely on conventional PWM commands.
The repository also includes firmware written using ESP-IDF and C++, along with drivers for sensors and actuators. The robot incorporates an OV2640 camera, VL53L0X time-of-flight distance sensor, MPU6050 inertial measurement unit and OLED display. Developers can program it through the TNY-Coder block-based web application or extend its functionality using the firmware and documented interfaces. The expansion port also provides a route for adding sensors and other peripherals.
TNY Robotics invites developers to contribute software improvements, hardware revisions and bug reports through GitHub issues and pull requests. Its documentation covers component sourcing, PCB assembly, servo modification, calibration and software development, helping users reproduce and extend the design. Although the non-commercial licence restricts commercial reuse under its terms, the project provides a practical starting point for studying quadruped mechanics, embedded control and modular robotics without designing every component from scratch.
For more information, click here.